Skip to content
QAYRAALMILA
TR

Sea · Targeting TEKNOFEST 2027

ALMILA — Unmanned Underwater Vehicle

Master the depths. ALMILA is a next-generation autonomous underwater vehicle designed for complex missions and powered by modular robotics and AI.

About

Focus

The target is the TEKNOFEST 2027 Unmanned Underwater Systems Competition. Its tasks: finding lines and pipelines by vision, holding depth and heading, travelling to a given position on its own and deploying a small robot into a pipeline. The vehicle has to stay small and light (targets: under 60 cm in its largest dimension and under 12 kg) and protect itself against leaks and loss of link.
Approach

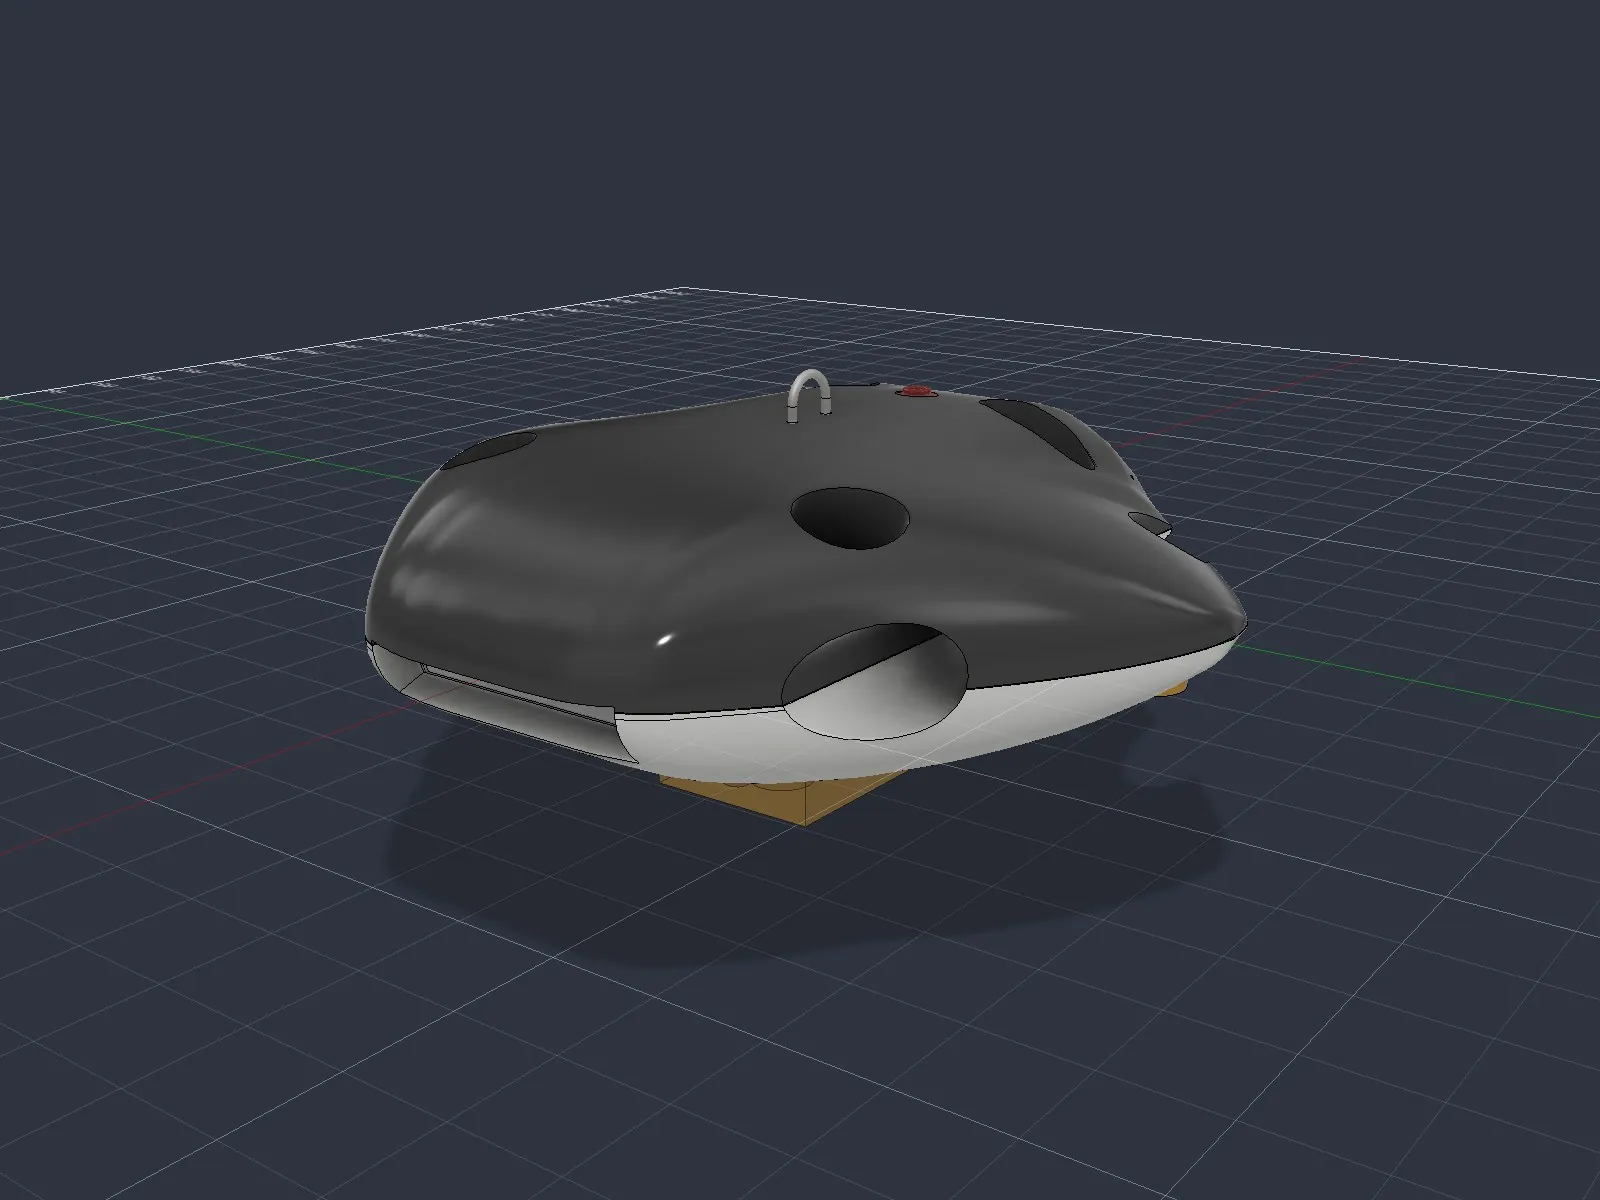
Software: AI-based object detection and our own mission planner; one computer handles vision and the mission, an autopilot holds depth and heading. Mechanical: a cage-less, enclosed ray-shaped hull; 8 thrusters sit in tunnels inside the hull (no exposed propellers) and move the vehicle in 6 degrees of freedom, while piston ballast tubes on both sides trim buoyancy. Electrical: our own power distribution board; electronics and battery live in a watertight aluminium tube in the centre. The vehicle talks to the shore over a fibre-optic tether, and a magnetic emergency-stop switch on its back cuts the battery. A Mini ROV carried under its belly is deployed into the pipeline.

Role
QAYRA · Design, build and software
Timeline
2026 — ongoing

Technologies

  • Autonomous navigation
  • Computer vision and AI
  • Underwater mechanics
  • Power electronics
  • Modular robot arm

Highlights

8

Thrusters

8 thrusters in tunnels inside the hull; the vehicle moves in 6 degrees of freedom with no exposed propellers.

Ray-shaped hull

A cage-less, enclosed hull; electronics and battery in a central watertight tube, ballast tubes on the sides.

Safety

A magnetic emergency stop cuts the battery; if a leak is detected the vehicle surfaces.

Modular robot arm

One design, multi-domain — with a universal mounting interface the arm fits sea, air and land vehicles without modification: underwater sampling, aerial grasping and payload delivery, debris removal on the ground.

Mini ROV

A small robot carried under the belly is released into the pipeline; its video reaches the shore over the main tether.

Vehicle and system architecture

A next-generation autonomous underwater vehicle designed for complex missions, built on modular robotics and AI.

Software

AI and mission planning

Object detection from the camera runs on the onboard embedded computer; the mission planner is our own software.

Mechanical

Hydrodynamic hull

An eight-thruster layout for six-degree-of-freedom, omnidirectional movement.

Electrical

Power distribution

Our own power distribution board with isolated noise filtering.

Modular robot arm: one design, three domains

Thanks to a universal mounting interface, the arm fits air, land and sea platforms without modification.

Sea · USV / AUV

Underwater manipulation

Underwater grasping and sample collection.

Integrated on ALMILA

Air · UAV

Aerial grasping

Aerial grasping and payload delivery.

Lightweight carbon fibre build

Land · UGV

Disposal and debris removal

Explosive ordnance disposal (EOD) and debris removal.

High-torque configuration

Documents

Media and prototypes

Design renders — exterior, hull, shell, propulsion and ballast.

Team

The people behind the project.